









How to design magnetic clamping correctly
Magnetic clamping can significantly speed up production, simplify handling, and improve repeatability. In practice, however, it is not enough to know that a magnet holds. If you are considering how to design magnetic clamping, the details are what matter – the workpiece material, air gap, force direction, required accuracy, and the method of releasing the part. These are precisely the factors that distinguish a functional solution from an application that fails in operation.
What a Good Magnetic Clamping Design Must Solve
Magnetic clamping is not a universal replacement for mechanical fixtures. It is a technical solution that works very well where the type of part, contact surface, and operating load are clearly defined. It is most commonly used in machining, assembly, handling, welding, or the temporary fixation of parts.
The basic question is not how strong the magnet should be. The correct question is what force the clamping system must withstand in a specific direction and under specific conditions. A magnet usually resists pull-off forces perpendicular to the surface very well, but it handles shear loads significantly worse. If the part moves sideways during the process, friction between the contact surfaces becomes the deciding factor, not just the nominal holding force of the magnet.
When designing a system, it is therefore important to remember that catalog holding force values are typically specified under ideal conditions. This means a thick, flat, clean steel surface with no gap. Real applications often involve paint, scale, imperfect contact, or thin sheet metal. Each of these factors reduces effectiveness.
How to Design Magnetic Clamping According to the Application
Clamping a thin sheet metal part requires a different approach than clamping a massive steel block, and both differ from positioning small components in an assembly fixture. For a reliable design, it is first necessary to determine whether the magnet performs the primary clamping function or merely assists mechanical guidance.
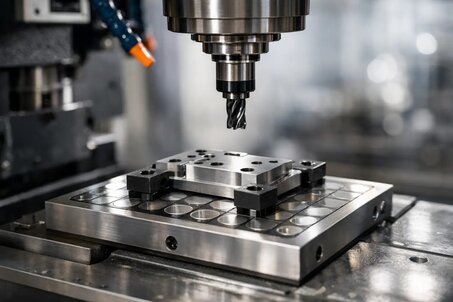
In machining applications, the critical factor is usually the combination of vertical and lateral forces. Milling or grinding creates dynamic loads and vibration, so it is not enough for the workpiece to simply stay attached to the table. It must also resist impacts and localized lifting. In such cases, a solution with fine pole spacing, a high-quality contact surface, and often additional stops is appropriate.
In assembly or handling applications, the speed of loading and unloading the part is often more important. Magnetic systems with simple operation or switchable magnets work well here. If the objective is only position fixation rather than transmitting large forces, the design can be considerably more compact.
In welding applications, temperature and contamination must be considered. Higher temperatures reduce the performance of many magnetic materials, while metallic contamination on contact surfaces affects the quality of contact. For this reason, magnets should not be selected solely according to maximum holding force, but also according to temperature stability and serviceability of the complete solution.
Key Parameters That Determine the Result
The material of the clamped part has the greatest influence. Ferromagnetic steels behave differently from stainless materials and completely differently from non-ferrous metals. Even among steels there are differences. Low-carbon structural steels generally clamp magnetically very well, while some alloyed or heat-treated materials may provide weaker results.
The second critical parameter is material thickness. Thin sheet metal cannot complete the magnetic circuit as effectively as a solid component. The result is lower holding force, even when the same magnet is used. For thin parts, a larger active area, different pole arrangement, or support from underneath often helps.
The air gap is a highly underestimated factor. A thin layer of paint, dirt, unevenness, or protective film is enough to cause a significant drop in force. Magnetic fields are highly sensitive to gaps. In practice, this means that contact accuracy is often just as important as the choice of magnet itself.
Finally, the direction of loading must be evaluated. If the magnet is intended to resist pull-off forces, the design is calculated differently than when it is intended to prevent lateral movement. Under shear loads, the coefficient of friction and surface quality become important. A smooth, oily, or ground surface can significantly reduce the safety margin.
Selecting the Magnet and Magnetic System
The magnet itself is only one part of the solution. Industrial applications usually require a magnetic system—a combination of the magnet, pole pieces, housing, shielding, and mechanical mounting. The system design determines how efficiently magnetic flux is transferred into the workpiece.
Neodymium magnets offer high force in compact dimensions, but operating temperature and application characteristics must be considered. Ferrite magnets are less powerful, yet sufficient in some conditions and suitable where extreme holding force is not required. SmCo magnets make sense at elevated temperatures or where special stability requirements exist, although designs using them are generally more expensive.
It is also important to decide whether the system should be permanent, switchable, or electromagnetic. Permanent solutions require no power supply and are suitable where continuous holding is required. Switchable magnets simplify operation and reduce risk during part loading. Electromagnets are ideal where controlled activation, automation, or machine integration is needed, but they must also be designed with power-failure safety in mind.
Mechanics Are Just as Important as Magnetism
A common mistake is assuming that a stronger magnet solves everything. It does not. If lateral guidance, stops, or a properly designed contact surface are missing, the magnetic system may have sufficient holding force and still leave the workpiece unstable during the process.
Good magnetic clamping therefore combines magnetic and mechanical functions. The magnet presses the workpiece against a reference surface, while mechanical elements absorb directional loads that should not rely solely on friction. Such a solution is typically more accurate, safer, and more repeatable over the long term.
How to Design Magnetic Clamping Safely
The safety margin should be based on the real process, not on ideal catalog values. If the application involves impacts, vibration, contamination, or dimensional variation of parts, the design must be able to absorb these deviations. In industrial practice, laboratory-calculated values are often insufficient without testing on the actual workpiece.
Special attention should be paid to lifting and handling applications. Here, the issue is not only accuracy or productivity but also the safety of operators and surrounding personnel. When lifting, not only the load weight but also its shape, thickness, contact area, center of gravity, and the possibility of detachment during tilting must be assessed.
A safe design also addresses part release. If the workpiece is difficult to remove from the magnet after the process is complete, operators often resort to unsuitable methods. This reduces time savings and can damage both the part and the fixture. Therefore, push-off elements, levers, switching mechanisms, or auxiliary demagnetization should already be considered during the design stage.
Typical Design Mistakes
The first is designing according to a specification table without verifying real operating conditions. The second is underestimating lateral forces and vibration. The third is using too small an active contact area, especially with thin or uneven workpieces.
Another common problem occurs when a magnetic system is built into unsuitable materials or geometry. Steel components in the wrong position can divert magnetic flux away from the working surface and reduce efficiency. Likewise, thermal loading without considering the limits of the selected magnet is inappropriate.
Practical experience reveals another mistake—ignoring maintenance. If dirt, burrs, or grinding dust accumulate on the pole surfaces, performance gradually declines. The design should therefore also consider easy cleaning and inspection.
Verifying the Design in Practice
Even a high-quality calculation has its limits because real magnetic clamping is influenced by many variables simultaneously. The most reliable approach is a combination of technical design, selection of a suitable system, and testing on the actual workpiece. Testing reveals whether the contact area is sufficient, how the workpiece behaves under load, and whether operators can perform the process without unnecessary time losses.
In practice, it is worth monitoring not only maximum force, but also loading repeatability, contact cleanliness, and behavior during serial production. A magnetic clamping system that works perfectly for one part on a bench may not perform equally well after hundreds of production cycles.
This is where professional consulting and experience with real-world applications become valuable. SELOS Magnety has specialized in magnetic solutions since 1991, and there is a significant difference between simply selecting a product and evaluating the entire system, including operating conditions.
If magnetic clamping is expected to work reliably, do not start with a catalog number. Start by asking what the workpiece must actually withstand in the process. The correct design does not begin with the strongest magnet—it begins with the most precisely defined application.